Computer Vision
We build detection, segmentation and tracking pipelines that run on the camera's own edge hardware, so the decision happens on the line or on the robot instead of in a data center.
Start a Project- Object Detection (YOLO)
- Semantic Segmentation
- Real-time Tracking
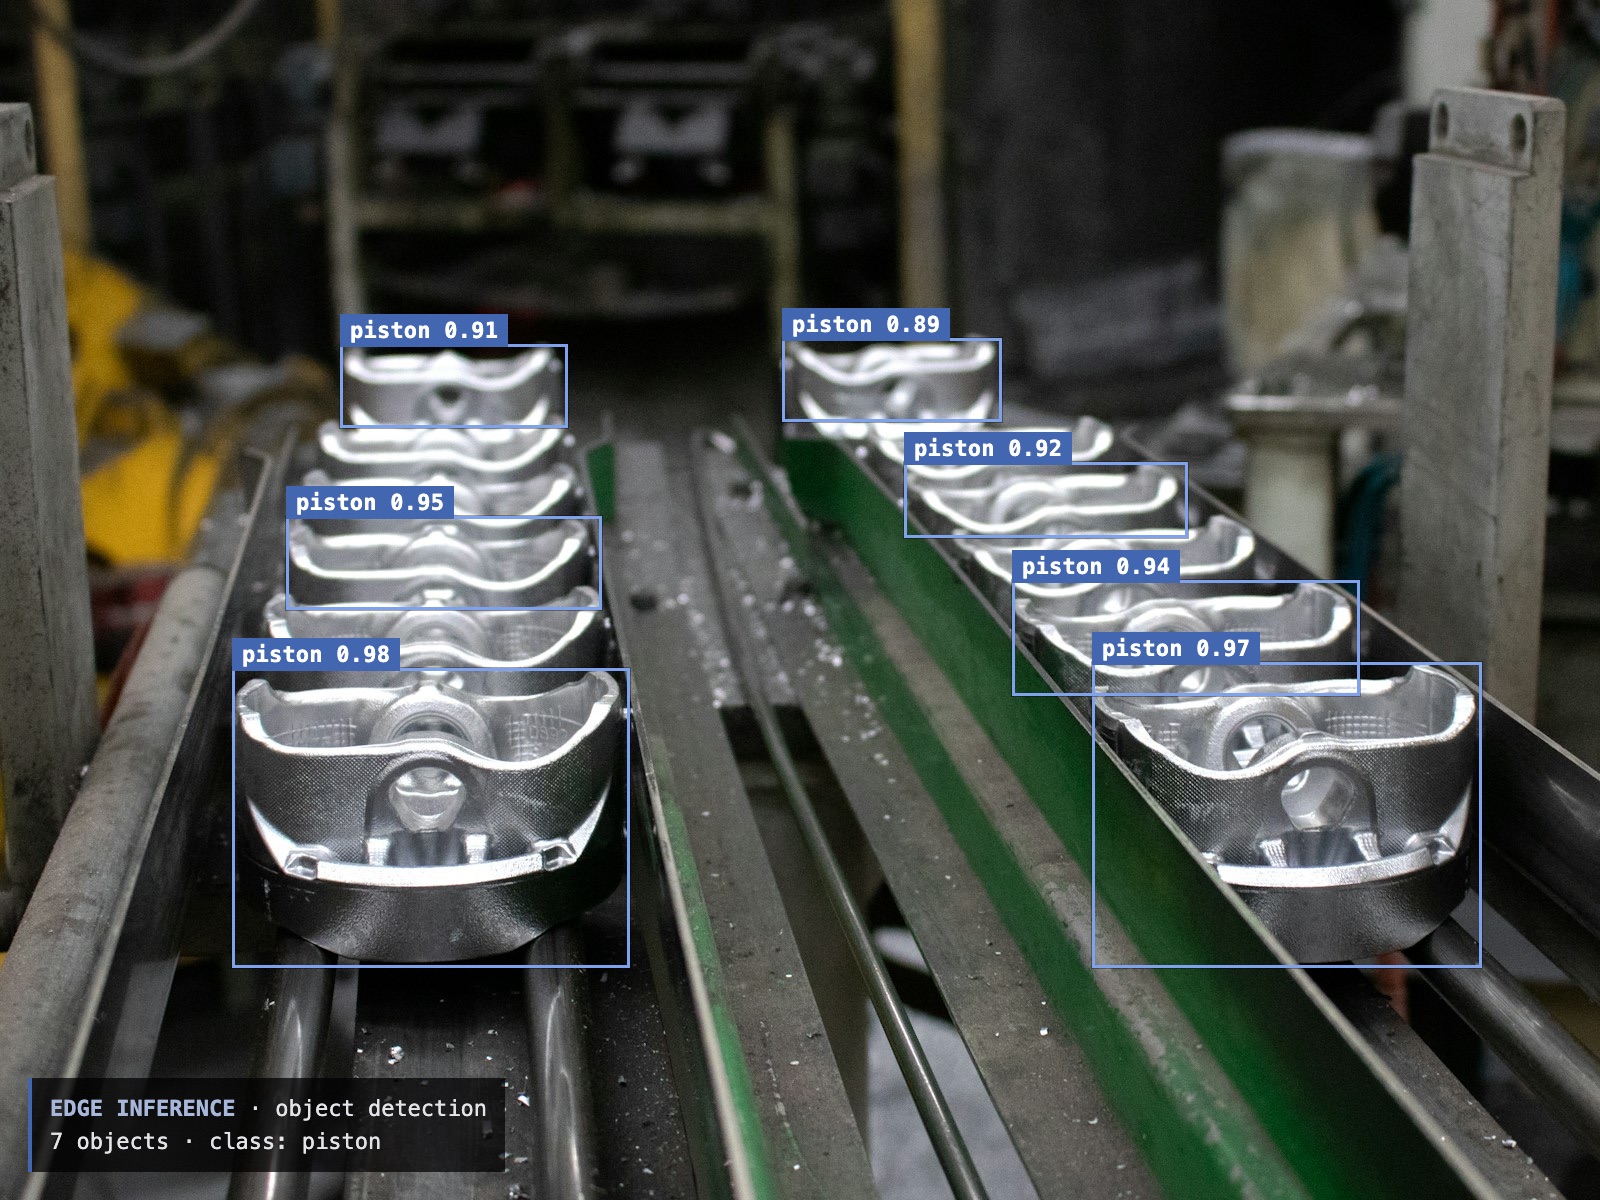
Why run vision on the edge?
Latency, bandwidth and privacy. A defect on a conveyor has to be flagged before the part moves on, and streaming every frame to the cloud costs more than the camera did.
What do we build?
- Object detection (YOLO family) trained on your images
- Semantic segmentation for terrain, surfaces or defects
- Real-time tracking across frames
- The full pipeline around the model: capture, preprocessing, inference and the output your system acts on
What hardware do we target?
Nvidia Jetson, Google Edge TPU and Raspberry Pi class boards, chosen by the frame rate and power you need. Model optimization is shared with our embedded AI work.
Where has this been tested?
For the International Rover Design Challenge we segmented Martian terrain (sand, rock, bedrock) from a stereo camera feed on an Edge TPU and turned it into a cost map for path planning. The team placed 11th globally.
Other services
Embedded AI
Constraint-Aware Model Optimization. Lossless INT8/FP16 quantization, weight pruning, and hardware-accelerate…
Robotics & Control
Deterministic Motion Planning. Real-time state estimation, 6-DOF trajectory generation, and closed-loop contr…
Industrial IoT
Cloud-native machines. Robust telemetry pipelines that handle millions of data points.
Backend & API
High-performance servers to manage your device fleet. Built with Django / FastAPI.
Ready to build something real?
Tell us the hardware, the constraint and the deadline. You'll talk to the engineer who'd do the work.
Start a Project